
HUMANOID CONFIGURATION / 2 WRISTS + 2 ANKLES
Plan a four-sensor
humanoid 6-axis
force sensor set
Review the hands and ground-contact load paths together. Select two wrist targets and two ankle targets, with separate force, moment and installation-space requirements.
This is an engineering set configuration. Final sensor ratings, matched electronics, mounting, software scope, set pricing and delivery require a written quotation.
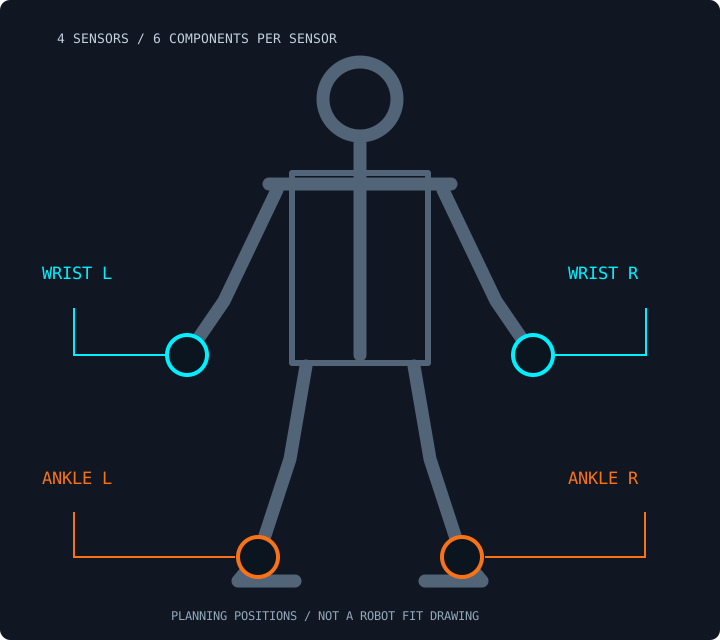
TWO LOAD PATHS / ONE DOCUMENTED SET
Size wrist contact and ankle impact independently
Two wrist sensing positions
Include gripper/tool mass, peak contact force, bending moments from the tool offset, hollow-bore requirements and cable motion.
Review wrist targets ↗Two ankle sensing positions
Define stance and impact loads, ground-plane transforms, fatigue cycles and mechanical stops. Wrist load ratings do not determine ankle capacity.
Review ankle targets ↗Acquisition and mounting scope
Request flange drawings, four serial-linked matrices, timestamps, bus topology, cable/pinout definitions and software compatibility for the complete set.
Choose engineering documents ↗Define a receiving test for all four sensors
- Match each sensor serial number to its six-channel range, reference frame and calibration matrix.
- Confirm each flange, fastener, cable exit and available space against the assembly drawing.
- Verify timestamps, signs, units, filter settings and dropped-frame handling on the chosen acquisition path.
- Review tare and tool/load transforms before using data in a balance or contact controller.
Each sensor has six measurement components. The set contains four sensors, not four measured force channels. Control-system qualification remains a separate assembly test.
CAPTURE THE WRIST AND ANKLE REQUIREMENTS
Request the two-wrist, two-ankle configuration
YOUR MAIL CLIENT / SAME ENGINEERING REQUEST
Send the selected model and specifications by email
The subject and message include the selected model, original reference, requested documents, loads and hardware options.
Read or manually copy the complete draft
To: inquiry@6axisforcesensor.com
Subject: HexaForce Four-sensor humanoid set — 2 wrist + 2 ankle set

Hello HexaForce engineering,

Request: Four-sensor humanoid set
Family: Please advise
HXF model / review target: Please advise
Original sensor / revision: Please advise
Application: Humanoid robot wrist or ankle
Target Fz (N) and Mxy (Nm): Please advise
Maximum OD and thickness (mm): Please advise
Preferred protocol: Help me select
Robot / tool / flange: Please advise
Quantity band: 4 units — wrist + ankle set
Quantity: 4
Delivery country / timeline: Please advise
Set composition: 2 × HXF-WRT80 (wrists) + 2 × HXF-ANK95 (ankles)
Wrist loads / space: Please advise / Please advise
Ankle Fz (N) and Mxy (Nm): Please advise
Ankle OD and thickness (mm): Please advise
Requested documents: STEP CAD & mechanical mounting drawing; Configuration-specific English datasheet; CAN-FD / serial / USB protocol documentation; Formal quotation / proforma invoice
Digital decoupling / software: confirm the selected configuration and tested release
Options: CNC robot wrist mounting adapter flange kit (+$145 budget)
Project notes:

Full name: [enter name]
Work email: [enter email]
Organization: [enter organization]
Source page: /humanoid-4-sensor-kit/
Please confirm drawings, capacity, output, calibration evidence, software scope, price and delivery before ordering.
The contact link carries technical selections. Personal contact details and project notes remain on this form.