
04 / HIGH CAPACITY / HXF-LRG
Large 6-Component Force Transducers
Specify a large six axis transducer around the complete test fixture. Reaction loads, moment arms, sealing and calibration uncertainty matter alongside rated capacity.
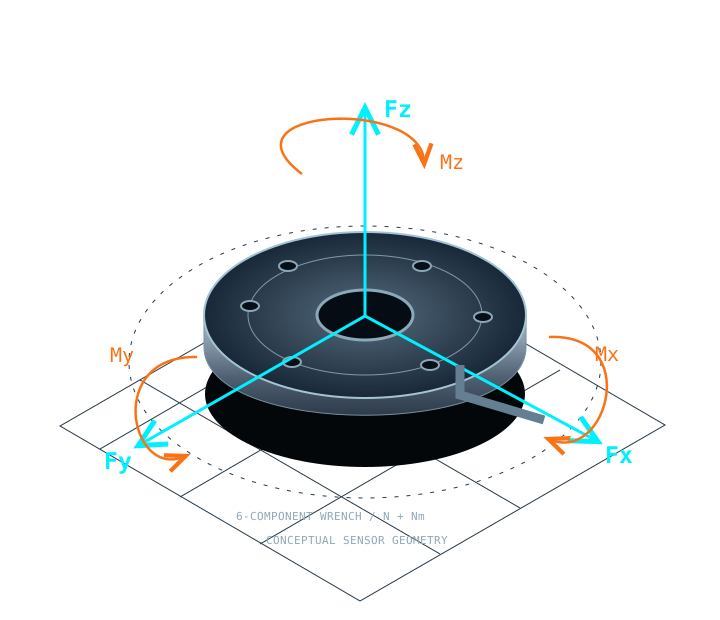
SIX CHANNELS / SPECIFY TOGETHER
HXF-LRG force, moment & installation envelope
These owner-requested family targets support an engineering discussion. They are not simultaneous ratings for a released model. Weight, resolution and combined-load boundaries require a selected configuration.
CHOOSE A MODEL TARGET / 3 REVIEW PATHS
Select geometry and six-channel requirements by model
Numeric entries below are requested design or reference-matching targets. They are not released HXF ratings. Engineering confirms the drawing, mass, simultaneous-load limits and selected interface before ordering.
| Model (HXF-xxx) | Fx, Fy (N) | Fz (N) | Mx, My (Nm) | Mz (Nm) | Dia. × Thickness (mm) | Weight (g) | Direct Interface |
|---|---|---|---|---|---|---|---|
| HXF-LRG160Drawing review | Specify | Specify | Specify | Specify | Ø160; thickness by drawing | Confirm | EtherCAT / CAN-FD / USB / RS485: select for review |
| HXF-LRG200-SUBDrawing review | Specify | Specify | Specify | Specify | Ø200; sealing by depth review | Confirm | EtherCAT / CAN-FD / USB / RS485: select for review |
| HXF-LRG300Drawing review | Specify | Specify | Specify | Specify | Ø300; thickness by drawing | Confirm | EtherCAT / CAN-FD / USB / RS485: select for review |
HXF-LRG160 — 160 mm test-rig target
Wind-tunnel fixtures and high-stiffness test assemblies.
- Select all force and moment ranges independently.
- State fixture tare, load origin and calibration requirements.
Original-reference names for review: ATI Omega160. Mounting, electrical and software interchange are not yet approved.
HXF-LRG200-SUB — 200 mm subsea test target
ROV thrust and submerged six-component tests.
- Provide immersion depth, duration, fluid and pressure cycles.
- Match the sealed connector, cable and fixture load path.
Original-reference names for review: ATI Omega190 / Omega191; ME-Meßsysteme K6D175. Mounting, electrical and software interchange are not yet approved.
HXF-LRG300 — 300 mm high-capacity target
Large test fixtures and suspension-load measurement.
- Provide the original installation drawing and six-component load history.
- Review adapter stiffness and combined-force/moment limits.
Original-reference names for review: ATI Omega250 / Omega331; Interface 6A. Mounting, electrical and software interchange are not yet approved.
Noise at your bandwidth
Request Fx/Fy/Fz resolution in N and Mx/My/Mz in Nm at a stated filter setting and sample rate. No measured HXF noise report is published here.
Residuals under combined load
Review six-axis calibration residuals and temperature drift. A requested <1% target needs a defined denominator and acceptance test.
Axis limits are not additive
Request a combined-load diagram, installation torque and shock limits. A 300–500% design target is not a universal working-load rating.
APPLICATION & FLANGE REVIEW
Confirm the complete HXF-LRG load path
Wind tunnel balances, suspension test rigs and underwater ROV thrust testing.
Subtract fixture tare and transform loads to the stated reference origin.
Subsea sealing requires depth, pressure, fluid, connector and immersion-duration specifications.
Load adapters and the calibration rig must cover the actual six-component working envelope.
Replacement references: ATI Omega190, ME-Meßsysteme K6D175 and Interface 6A reference-interface review. Third-party brands are unaffiliated. No mounting or protocol interchange is approved without a drawing and firmware review.
Open the replacement review checklist ↗INTEGRATE THE DATA, NOT JUST THE DISC
One six-component measurement chain
Choose the host interface, timestamps, axis convention and filtering with the sensor. Request the configuration-matched ESI or protocol document, tested software and commissioning checklist.
# Integration target — not an available driver download
# After installing the confirmed firmware-matched package:
ros2 launch hexaforce_ft_driver sensor.launch.py

# Inspect six channels in the sensor reference frame
ros2 topic echo /hexaforce/wrench
Request tested ROS1 / ROS2 Humble or Jazzy support, C++ / Python examples and Windows GUI availability with your quotation. No HXF driver or SDK release has been published here yet.
ENGINEERING REQUEST / HXF-LRG
Configure the sensor and robot mounting kit
YOUR MAIL CLIENT / SAME ENGINEERING REQUEST
Send the selected model and specifications by email
The subject and message include the selected model, original reference, requested documents, loads and hardware options.
Read or manually copy the complete draft
To: inquiry@6axisforcesensor.com
Subject: HexaForce Engineering quotation — HXF-LRG

Hello HexaForce engineering,

Request: Engineering quotation
Family: HXF-LRG
HXF model / review target: Please advise
Original sensor / revision: Please advise
Application: Please advise
Target Fz (N) and Mxy (Nm): Please advise
Maximum OD and thickness (mm): Please advise
Preferred protocol: Help me select
Robot / tool / flange: Please advise
Quantity band: Please advise
Quantity: Please advise
Delivery country / timeline: Please advise
Requested documents: Configuration-specific English datasheet; Formal quotation / proforma invoice
Digital decoupling / software: confirm the selected configuration and tested release
Options: CNC robot wrist mounting adapter flange kit (+$145 budget)
Project notes:

Full name: [enter name]
Work email: [enter email]
Organization: [enter organization]
Source page: /large-6-component-force-transducers/
Please confirm drawings, capacity, output, calibration evidence, software scope, price and delivery before ordering.
The contact link carries technical selections. Personal contact details and project notes remain on this form.
BEFORE YOU SPECIFY
Six-channel selection questions
Does each family cover every listed range at every size?
No. Values are design targets across a family. The selected configuration needs its own six-channel range, mass, dimensional drawing, output option and calibration record.
Can I replace an ATI, Bota or OnRobot sensor directly?
Send the original part number, drawing and firmware/protocol details. Matching outer diameter alone does not establish bolt-pattern, connector, axis-sign or software compatibility.
How do I specify resolution and crosstalk?
State your minimum detectable force and moment, bandwidth and temperature range. Request per-channel noise, resolution and combined-load residuals at those settings; output bit depth alone is insufficient.
Are the shown diagrams product photographs?
They are original conceptual engineering illustrations. They do not establish a supplied model, hole pattern, physical test result or manufacturing certification.
DEFINE THE COMPLETE LOAD CASE
Send the force. Add the moment arm.
Include your six-channel loads, robot model, space envelope and preferred interface. Request a configuration-specific quotation and STEP drawing.